Taking Custom Design to New Levels
PROUD TO BE PART OF THE BRIN FAMILY OF COMPANIES
OTHER BRIN LOCATIONS
Brin Glass Company | Minneapolis, MN
St. Germain’s Glass | Duluth, MN
Heartland Glass | Waite Park, MN
Choosing the right robot technology can reshape daily operations, but the best option is rarely the newest machine. It must fit your workflow, workforce, facility, and business goals. A robotic arm may suit precise assembly, while an autonomous mobile robot may improve movement between storage and production areas. The difference becomes clear on the factory floor.
The details matter. Start with the task, not the product brochure. Measure cycle times, error rates, floor space, payload needs, and operator involvement. Check whether the system can connect with existing software and equipment. Reliable vendors should explain maintenance schedules, training requirements, integration limits, and expected operating costs. Independent testing, documented safety practices, and relevant industry certifications can provide stronger evidence than bold marketing claims.
Fit comes first. A small pilot can reveal problems that spreadsheets miss, such as poor lighting, narrow aisles, unstable parts, or confusing user interfaces. It may also show that automation is unnecessary for one process. That is not a failure. It is useful evidence. Businesses should compare productivity gains with installation time, downtime risks, energy use, and long-term support. Robot technology should support people, not simply replace familiar routines without careful review. Expect trade-offs. The final choice should be practical, measurable, and flexible enough to grow with changing demand.
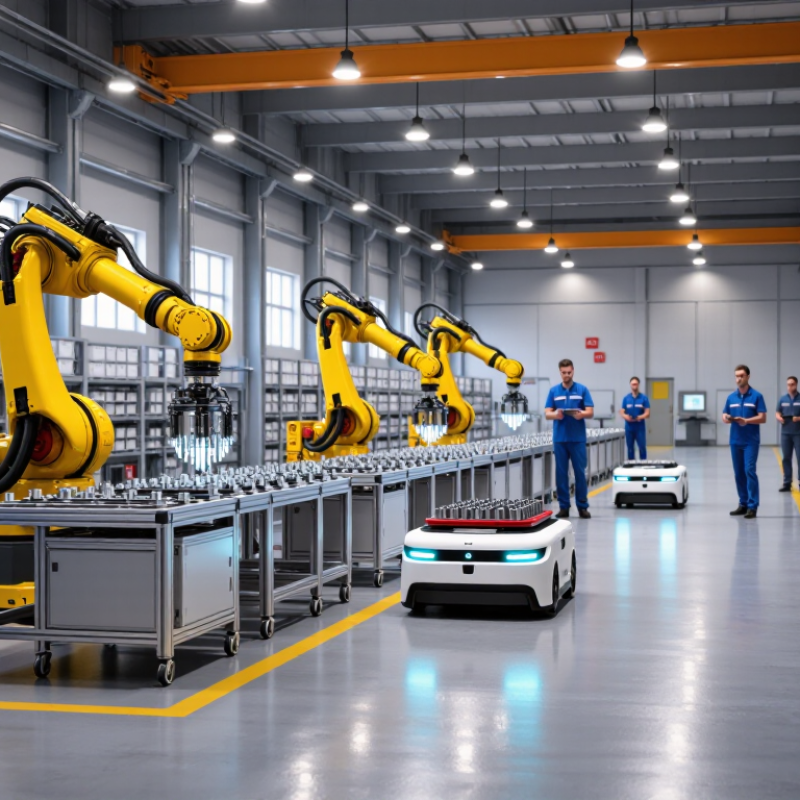
Choosing robot technology starts with business goals, not impressive specifications. Define the problem in measurable terms. A warehouse may need faster picking, while a factory may need steadier quality. Record cycle time, error rates, labor availability, floor space, and safety constraints. Include the people who operate the process daily. Their practical experience often exposes hidden delays.
The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. That figure shows strong adoption, but it does not prove every task needs a robot. A small, repetitive process may need a simple automated arm. A changing workflow may require vision systems or mobile movement. Calculate expected output, maintenance time, training costs, and payback period. Deloitte’s manufacturing research also highlights workforce shortages as a major automation driver. Still, replacing people is a weak goal. Improving safety and reducing exhausting repetition are better starting points. I have seen projects fail because managers measured speed before defining quality. That mistake is easy to repeat.
Tips: Write one clear automation target. For example, “reduce packing errors from 6% to 2% within six months.” Test the target with real shift data. Observe the robot beside workers, cartons, tools, and uneven lighting. Ask what happens during product changes. A perfect demonstration can hide ordinary problems. Leave room for doubt. Pilot the smallest useful task, then review results weekly. Keep a record of downtime, operator feedback, and unexpected repairs. These details will guide a more suitable technology choice.
Choosing robot technology begins with the work, not the machine. Start with the task.
Define the load, cycle time, workspace, surface, and expected operating hours. A small mobile robot may suit indoor transport, while a robotic arm may handle repetitive assembly or inspection. The right choice depends on actual conditions, not impressive demonstrations.
Assess capabilities using measurable criteria.
Check payload, reach, repeatability, navigation accuracy, sensing, and safe stopping behavior. Also examine software compatibility, maintenance access, training needs, and energy use. A robot that moves quickly may still perform poorly when lighting changes or floors become uneven. Measure twice. Speak with operators who will use the system daily.
Technology options should fit your existing process. Look for clear data interfaces, practical integration tools, and flexible programming.
During a pilot, record completed cycles, human interventions, downtime, and defect rates. Calculate the full cost, including setup, support, spare parts, and workflow changes.
In my experience, teams often underestimate integration time. I have also seen pilots fail because workers were consulted too late. That weakness deserves attention. A controlled trial can reveal awkward handoffs, noisy sensors, or tasks the robot cannot reliably repeat. Use those findings to adjust the design before expanding deployment.
A suitable robot must fit your existing workflow, not disrupt it. Start by mapping each task, handoff, and data connection. Check whether the system communicates with your equipment and software. Integration failures often appear during small transitions, such as loading, inspection, or packaging. Ask the supplier for a live demonstration using your materials and workspace. A controlled trial reveals more than a polished presentation.
Safety requires more than an emergency stop. Review movement zones, access points, speed limits, and unexpected restart risks. Operators should understand normal use, fault responses, and daily inspection steps. Document risk assessments and maintenance records clearly. An independent safety professional can challenge assumptions your internal team may overlook. That outside view matters. I have seen projects delay training because the technology seemed simple. The delay created avoidable confusion.
Workplace compatibility also includes people, noise, lighting, floor space, and changing production demands. Measure clearance around the robot, including space for maintenance. Observe how employees move during busy periods. A system may work perfectly in testing yet obstruct a frequently used walkway. Speak with operators before final selection. Their practical experience can expose awkward controls or unrealistic cycle times. Not every issue has a quick fix. Be willing to revise the layout, training plan, or automation scope. The best choice supports safer work and steady cooperation, rather than pursuing maximum automation at any cost.
Choosing robot technology starts with total cost, not the purchase price. A warehouse project may require installation, integration, staff training, safety checks, maintenance, energy, and software updates. Include production downtime during commissioning. A low quote can age badly.
Build a three-year and five-year cost model using documented assumptions. Ask how replacement parts, technical support, and system changes are priced. Then test the model against one real workflow, such as moving 600 cartons across a 200-square-meter area each day. Record labor hours, errors, delays, and maintenance time before automation. These figures create a credible baseline.
Scalability matters when demand changes. A suitable system should expand without forcing a complete redesign. Check whether it can handle extra units, new product sizes, higher order volume, and additional work areas. Growth is rarely smooth. Seasonal peaks may expose limits that a small pilot misses.
Expected return should combine financial and operational results. Calculate payback from measurable savings, added output, reduced errors, and improved worker utilization. Use conservative assumptions, not ideal performance. For example, a forecast based on 95% uptime should also show results at 85%. An independent review can challenge optimistic figures. Forecasts remain imperfect, and my own early estimates have sometimes ignored integration delays. That weakness is useful when it becomes visible before investment.
Compare Total Costs, Scalability, and Expected Return
The comparison uses typical planning benchmarks for a three-year deployment. Collaborative robot cells generally require the lowest initial investment, autonomous mobile robot fleets provide stronger expansion potential, and fixed automation can deliver high throughput when processes are stable and repetitive. Actual results depend on labor costs, utilization, integration requirements, and operating conditions.
How to Choose the Right Robot Technology for Your Business?
Select, Test, and Implement the Right Robot Solution
Selecting robot technology should begin with the task, not the machine. Observe the work area during a normal shift. Record cycle time, lifting distance, error rates, and operator movement. A warehouse may need mobile transport, while a production line may require precise handling. Talk with the people who perform the work daily. Their practical experience often reveals problems that spreadsheets miss.
Test a small, realistic pilot before approving a full installation. Use the actual materials, lighting, floor conditions, and shift patterns. Measure output, downtime, maintenance effort, and worker acceptance. A successful demonstration in an empty room proves very little. Our first estimate was too optimistic because we ignored cleaning interruptions. That mistake changed our testing checklist. Small failures are useful.
Implementation requires preparation beyond installation. Train operators with clear procedures and simple recovery steps. Check workspace safety, access controls, emergency stops, and applicable workplace requirements. Connect the robot with existing production or inventory systems only after data flows are verified. Assign one person to monitor performance during the first weeks. Review the results weekly, but avoid changing several variables at once. The right solution may be less advanced, yet easier to maintain, measure, and improve.
| Robot Technology | Typical Payload and Reach | Typical Repeatability | Best-Fit Business Applications | Key Selection Criteria | Integration Complexity | Relative Investment | Recommended Pilot Priority |
|---|---|---|---|---|---|---|---|
| Collaborative Robot Arm | Approximately 3–20 kg payload; about 500–1,800 mm reach. | Commonly approximately ±0.02–0.10 mm, depending on model and operating conditions. | Machine tending, assembly, screwdriving, packaging, inspection, and low-to-medium volume production. | Part weight, cycle time, required reach, human interaction, safety concept, and end-of-arm tooling. | Low to medium; usually suitable for phased deployment and frequent product changeovers. | Low to medium. | High |
| Six-Axis Industrial Robot | Approximately 6–300 kg payload; about 1,000–3,500 mm reach. | Commonly approximately ±0.02–0.08 mm in industrial applications. | Welding, heavy machine tending, material handling, palletizing, painting, and high-volume production. | Payload and inertia, wrist orientation, duty cycle, environmental resistance, takt time, and safety guarding. | Medium to high; often requires dedicated fixtures, guarding, programming, and process engineering. | Medium to high. | Medium |
| SCARA Robot | Approximately 1–20 kg payload; about 400–1,000 mm horizontal reach. | Commonly approximately ±0.01–0.03 mm. | High-speed pick-and-place, electronics assembly, dispensing, insertion, and small-part handling. | Required horizontal speed, vertical stroke, insertion accuracy, part presentation, and cycle-time target. | Medium; mechanical fixtures and precise part orientation are usually required. | Medium. | High |
| Delta Robot | Typically 0.5–15 kg payload; commonly 600–1,600 mm working diameter. | Commonly approximately ±0.05–0.20 mm. | Very high-speed sorting, food handling, packaging, kitting, and lightweight pick-and-place tasks. | Part weight, product spacing, conveyor tracking, cleanliness requirements, allowable acceleration, and gripper design. | Medium; vision, conveyor synchronization, and product presentation are important. | Medium to high. | High |
| Automated Guided Vehicle | Commonly 0.5–5 tonnes per vehicle, depending on configuration and floor conditions. | Typical docking accuracy is approximately ±10–50 mm without advanced guidance features. | Warehouse transport, line-side replenishment, pallet movement, and repetitive internal logistics. | Load mass, route length, floor quality, traffic rules, charging strategy, docking accuracy, and fleet size. | Medium to high; warehouse-management, manufacturing-execution, and traffic-control integration may be needed. | Medium to high. | Medium |
| Autonomous Mobile Robot | Commonly 100–2,000 kg payload, depending on platform type and floor conditions. | Typical positioning accuracy is approximately ±10–50 mm in mapped indoor environments. | Flexible material transport, order fulfillment, kitting, hospital logistics, and dynamic facility movement. | Map stability, obstacle behavior, fleet management, route congestion, payload interface, and network coverage. | Medium; generally more flexible than fixed-route vehicles but dependent on software and site readiness. | Medium to high. | High |
| Automated Palletizing Robot | Approximately 50–300 kg payload; about 2,000–3,500 mm reach. | Commonly approximately ±0.05–0.20 mm. | Case packing, palletizing, depalletizing, warehouse loading, and repetitive end-of-line operations. | Case dimensions, pallet pattern, product stability, required cases per minute, gripper type, and line speed. | Medium to high; usually requires conveyors, pallet dispensers, safety systems, and line controls. | Medium to high. | High |
| Robotic Vision Inspection System | Payload depends on the selected robot; inspection cameras typically operate over a defined field of view rather than a payload range. | Measurement capability commonly ranges from sub-millimeter to several millimeters, depending on optics, lighting, calibration, and part geometry. | Presence checks, dimensional inspection, surface inspection, label verification, sorting, and defect detection. | Defect size, contrast, lighting, camera resolution, inspection speed, false-reject tolerance, and data traceability. | Medium; the largest risks are often application lighting, image variability, and data integration. | Low to high, depending on accuracy and inspection scope. | Medium |
| Robotic Welding Cell | Commonly 6–25 kg wrist payload; approximately 1,400–2,500 mm reach. | Commonly approximately ±0.05–0.10 mm for programmed positioning. | Repeatable welding of medium-to-high volume assemblies with stable joint geometry. | Joint access, weld length, fixture repeatability, material, distortion, torch clearance, and operator safety. | High; requires process qualification, fixtures, welding equipment, guarding, extraction, and skilled commissioning. | High. | Low |
| Robotic Machine-Tending Cell | Approximately 3–50 kg payload; reach commonly 700–2,000 mm. | Commonly approximately ±0.02–0.10 mm. | CNC loading and unloading, press tending, injection-molding support, and repetitive part transfer. | Machine interface, door and chuck signals, part presentation, chip and coolant exposure, cycle time, and access. | Medium; success depends on reliable machine communication and consistent fixtures. | Medium to high. | High |
Taking Custom Design to New Levels

Brin Glass Company | Minneapolis, MN
St. Germain’s Glass | Duluth, MN
Heartland Glass | Waite Park, MN

Fabricator
Inside Sales and Client Support Manager
Glass Handler – 1st Shift