How to Choose a Six Axis Robot for Your Business
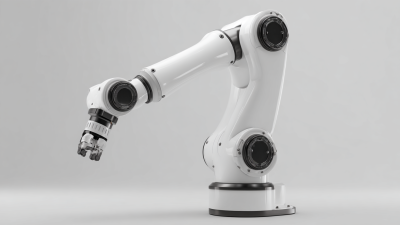
Choosing a six axis robot is not simply a matter of selecting the arm with the largest payload. The right model must fit the actual task, work envelope, cycle time, and factory layout. A robot that lifts a heavy part may still be unsuitable if its reach is too short or its wrist cannot approach the fixture cleanly. Small details matter. A cable snag, awkward tool angle, or crowded cell can slow production every shift.
Joseph Engelberger, an industrial robotics pioneer, is often quoted as saying, “I can’t define a robot, but I know one when I see one.” That memorable line speaks to recognition, not purchasing advice. For a business, practical evidence matters more: validated payload and reach data, repeatability specifications, integration requirements, service access, and support availability. Ask suppliers to demonstrate the intended task with the actual gripper, part, and motion path where possible. Watch the complete cycle. Measure it.
This guide outlines how to compare six axis robot options, from application requirements to installation and long-term operating costs. It also considers controller compatibility, programming skills, and the space needed for safe maintenance. Not every production line needs the fastest arm. Sometimes, a simpler model is the better fit. One caution: estimates made before testing can miss real-world delays. Treat them as estimates, then verify them on the shop floor.
Define the Tasks and Production Requirements
Before selecting a six-axis robot, write down the exact jobs it must perform. Is it loading a press, tending a machine, welding a frame, or moving cartons? Describe each cycle from pickup to release, including part weight, reach, tool changes, and required accuracy. A 12-kilogram component may need a higher-payload robot once the gripper and cables are included. Measure the actual work envelope, not just the distance between two points. Small fixtures matter.
Tips: Observe a full production shift before estimating cycle time. Record the slowest handoff, not only the robot’s motion. Check how often operators change parts or clear jams. These details can affect the cell layout.
Then define production targets: units per hour, shifts per day, changeover frequency, and acceptable downtime. Note whether products vary in size or arrive unpredictably. These conditions affect payload, reach, repeatability, mounting position, and end-effector choice. Compare the required cycle time with the complete process, including doors, sensors, and safety stops. A robot may move quickly, yet the line can still wait on a fixture. Be honest about uncertainty. An initial estimate can look too neat; validate it with sample parts and a timed trial before finalizing specifications.
Assess Payload, Reach, Speed, and Accuracy
Choosing a six-axis robot starts with the part, tool, and task—not the largest number on a specification sheet. Payload must include the gripper, cables, and workpiece, with room for acceleration and wrist forces. A 10-kilogram load may feel heavier to the robot when it extends horizontally. Check the manufacturer’s load charts, not payload alone.
Reach is measured from the robot’s base, but the usable workspace depends on posture and obstacles. Map the full path, including approach angles and tool changes. Then assess speed against the actual cycle: fast joint motion may not shorten a process that needs careful placement. Accuracy also needs context. Repeatability describes how consistently the robot returns to a position; it does not guarantee perfect absolute positioning. A spreadsheet can make this look settled. It rarely is.
Tips: Test with the real tool and a representative part. Measure cycle time at the required accuracy, and watch for vibration near extended positions. Ask whether the robot can reach every point without awkward wrist rotations. Small setup details matter. Leave clearance for cables, fixtures, and maintenance access. If the first layout only works on screen, revisit it before purchase.
Compare Robot Features and Integration Requirements
When choosing a six-axis robot, compare more than payload and reach. A 10-kilogram rating may not include a long gripper, cables, and the part together. Check wrist load, center of gravity, and tool inertia against your real setup. Reach diagrams matter, too: a robot may reach a fixture but approach it at an awkward angle. Compare repeatability, speed under load, protection rating, and access for maintenance. Precision is not everything.
Tips: Map the robot’s full path, including tool changes and nearby fixtures. Confirm mounting space, cable routing, controller placement, and available power. Ask how the robot will exchange signals with your PLC, sensors, and safety equipment. A short simulation can reveal collisions before installation.
Integration can take longer than expected. Review programming skills on your team, spare-part access, and support response times before choosing a model. One detail is easy to overlook: a tool change can alter reach and cycle time. Test with representative parts, not just an ideal sample. Even a careful plan may need adjustment once the cell is running.
Evaluate Safety, Costs, and Ongoing Support
A six-axis robot should be judged by the work cell it will enter, not by payload alone. Check reach, tool weight, cycle time, and the space needed for guarding. Then map hazards around the full arm path, including setup, teaching, and maintenance. The U.S. Bureau of Labor Statistics reported a 2.4 injury-and-illness rate per 100 full-time workers in private industry for 2023. That figure is not robot-specific, but it is a reminder to assess the whole workplace. Ask for a documented risk assessment, safety-device validation, and training for operators and technicians. A test run helps. Watch the robot stop near a person, recover from a fault, and restart only under controlled conditions.
Purchase price is only one line in the budget. Include integration, end-of-arm tooling, guarding, programming, spare parts, training, and planned downtime. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, with 4.28 million units operating globally. A large installed base makes parts and qualified service worth checking before purchase. Request written response times, remote-support limits, local technician coverage, and expected spare-part lead times. Downtime is expensive. Calculate the cost of a missed shift, not just an hourly service fee. Compare energy use and maintenance intervals across realistic production cycles. One detail is easy to overlook: a technically capable robot can still become a poor investment if staff cannot troubleshoot ordinary faults. Ask the integrator to train the people who will actually run the cell, then verify that they can perform a safe recovery without guesswork.
How to Choose a Six-Axis Robot for Your Business
Compare safety, capability, total cost, integration, and ongoing support before selecting a robot.
Example planning weights, not universal industry benchmarks: safety receives the highest share, followed by payload and reach, total cost, integration, and ongoing support. Adjust the weights to reflect your application, risk assessment, and service requirements. A six-axis robot has six independently controlled axes; suitability also depends on the specific task, tooling, workspace, and safety system.
Validate the Selection with Simulation and Pilot Testing
Simulation can reveal whether a six-axis robot fits your real workspace before equipment is installed. Build a digital cell using measured aisle widths, fixture positions, and part dimensions. Include cables, grippers, and nearby machines; these are easy to overlook. Then test the proposed reach, joint limits, and motion paths across the full task cycle. A smooth animation is not proof of a reliable process.
Check cycle time under realistic conditions, including part variation and brief pauses for loading. Look for wrist flips, awkward approach angles, and collisions near fixtures. Small changes matter. A five-millimeter shift can affect clearance or gripping consistency. Simulation estimates performance, though its assumptions may be wrong. Record them and review the model with operators and maintenance staff.
Follow with a controlled pilot using representative parts and the intended end-of-arm tooling. Track cycle-time spread, placement accuracy, missed picks, and recovery time—not just the best run. Run enough cycles to expose heat, wear, or inconsistent feeding; one shift may still miss problems that appear later. Document each adjustment and retest the changed task. If results fall short, pause and revisit the payload, reach, or layout rather than forcing the original selection.
How to Choose a Six Axis Robot for Your Business - Validate the Selection with Simulation and Pilot Testing
Representative planning estimates for screening robot configurations. Confirm final specifications, cycle times, and safety requirements with the integrator and robot supplier.
| Selection dimension |
Configuration A
Compact handling |
Configuration B
General-purpose handling |
Configuration C
Heavy-part handling |
How to validate |
| Typical payload class |
6 kg |
12 kg |
20 kg |
Include the gripper, cables, sensors, and workpiece in the total wrist load. |
| Representative reach |
1.4 m |
1.6 m |
1.8 m |
Check every pickup and placement pose, tool orientation, and approach path in the cell layout. |
| Typical repeatability class |
±0.03 mm |
±0.05 mm |
±0.08 mm |
Compare the task’s actual tolerance with the specified repeatability; verify process accuracy separately. |
| Initial application fit |
Small components, machine tending, light packing |
Medium cartons, assembly, palletizing lighter cases |
Large parts, heavier packaging, higher-inertia handling |
Match the robot to the heaviest part and the required tooling, not just the average part. |
| Simulation checks |
Reach, wrist orientation, singularities, cycle time |
Reach, path clearance, cycle time, joint limits |
Payload and inertia, reach, clearance, cycle time |
Use the intended tool and realistic approach, dwell, transfer, and release motions. |
| Illustrative simulated cycle time |
4.2 s per pick-and-place cycle |
5.0 s per pick-and-place cycle |
6.1 s per pick-and-place cycle |
Treat simulation as an estimate; include gripper response, sensing, conveyor tracking, and process time. |
| Pilot-test acceptance measures |
Meet target rate; verify placement and grip reliability |
Meet target rate across representative product variants |
Meet target rate at maximum planned load and duty cycle |
Run production-representative trials and record cycle-time distribution, faults, quality, and recovery time. |
| Pilot duration and sample |
At least one full shift; 500+ cycles |
At least one full shift; 500+ cycles |
At least one full shift; 500+ cycles |
Extend testing when product variation, uptime risk, or process changes require more evidence. |
| Decision guidance |
Prefer when load and reach are comfortably within limits and floor space matters. |
Prefer when a balanced payload and reach cover several tasks. |
Prefer only when the payload or reach requirement justifies the larger configuration. |
Select the smallest configuration that passes simulation and pilot acceptance criteria with a practical operating margin. |
Fabricator
Inside Sales and Client Support Manager
Glass Handler – 1st Shift